Robotic Systems Design Project
A full-system robotics project covering navigation, perception, testing, evaluation and technical demonstration. The work connects software development with practical engineering evidence.
I am an MSc Robotics student at The University of Manchester with a background in Software Engineering. My current interests focus on autonomous robots, robot perception, navigation, control and applied machine learning.
This website presents my education, selected projects, technical skills and CPD evidence. It is also used as a portfolio to document my professional development during the MSc Robotics programme.
Navigation, path planning, control and system integration for mobile robots and robotic platforms.
Deep learning, computer vision and data-driven methods for perception and decision-making.
Object detection, depth sensing, sensor evaluation and practical perception pipelines for robotic tasks.
Experimental testing, performance comparison, data visualisation and evidence-based engineering conclusions.
This section summarises selected evidence from my MSc Robotics work.
A full-system robotics project covering navigation, perception, testing, evaluation and technical demonstration. The work connects software development with practical engineering evidence.
Implemented and tested autonomous navigation behaviours in simulation environments. This included path planning, controller tuning, goal reaching tests and analysis of performance under different conditions.
Developed object detection and depth-based localisation workflows using camera data. The objective was to support robotic decision-making with reliable target recognition and position estimation.
Designed practical tests to evaluate sensor behaviour, including measurement accuracy, repeatability and limitations. Results were analysed using plots and clear engineering conclusions.
Additional evidence can be linked here, such as GitHub repositories, technical videos, screenshots, reports or demonstration material.View GitHub profile
A team-based robotics design project focused on developing a robot that can autonomously search for coloured objects, retrieve them, return to the starting point, and place them into a matching coloured bin. My main responsibility was object detection, supporting the robot in identifying target objects during the retrieval task.

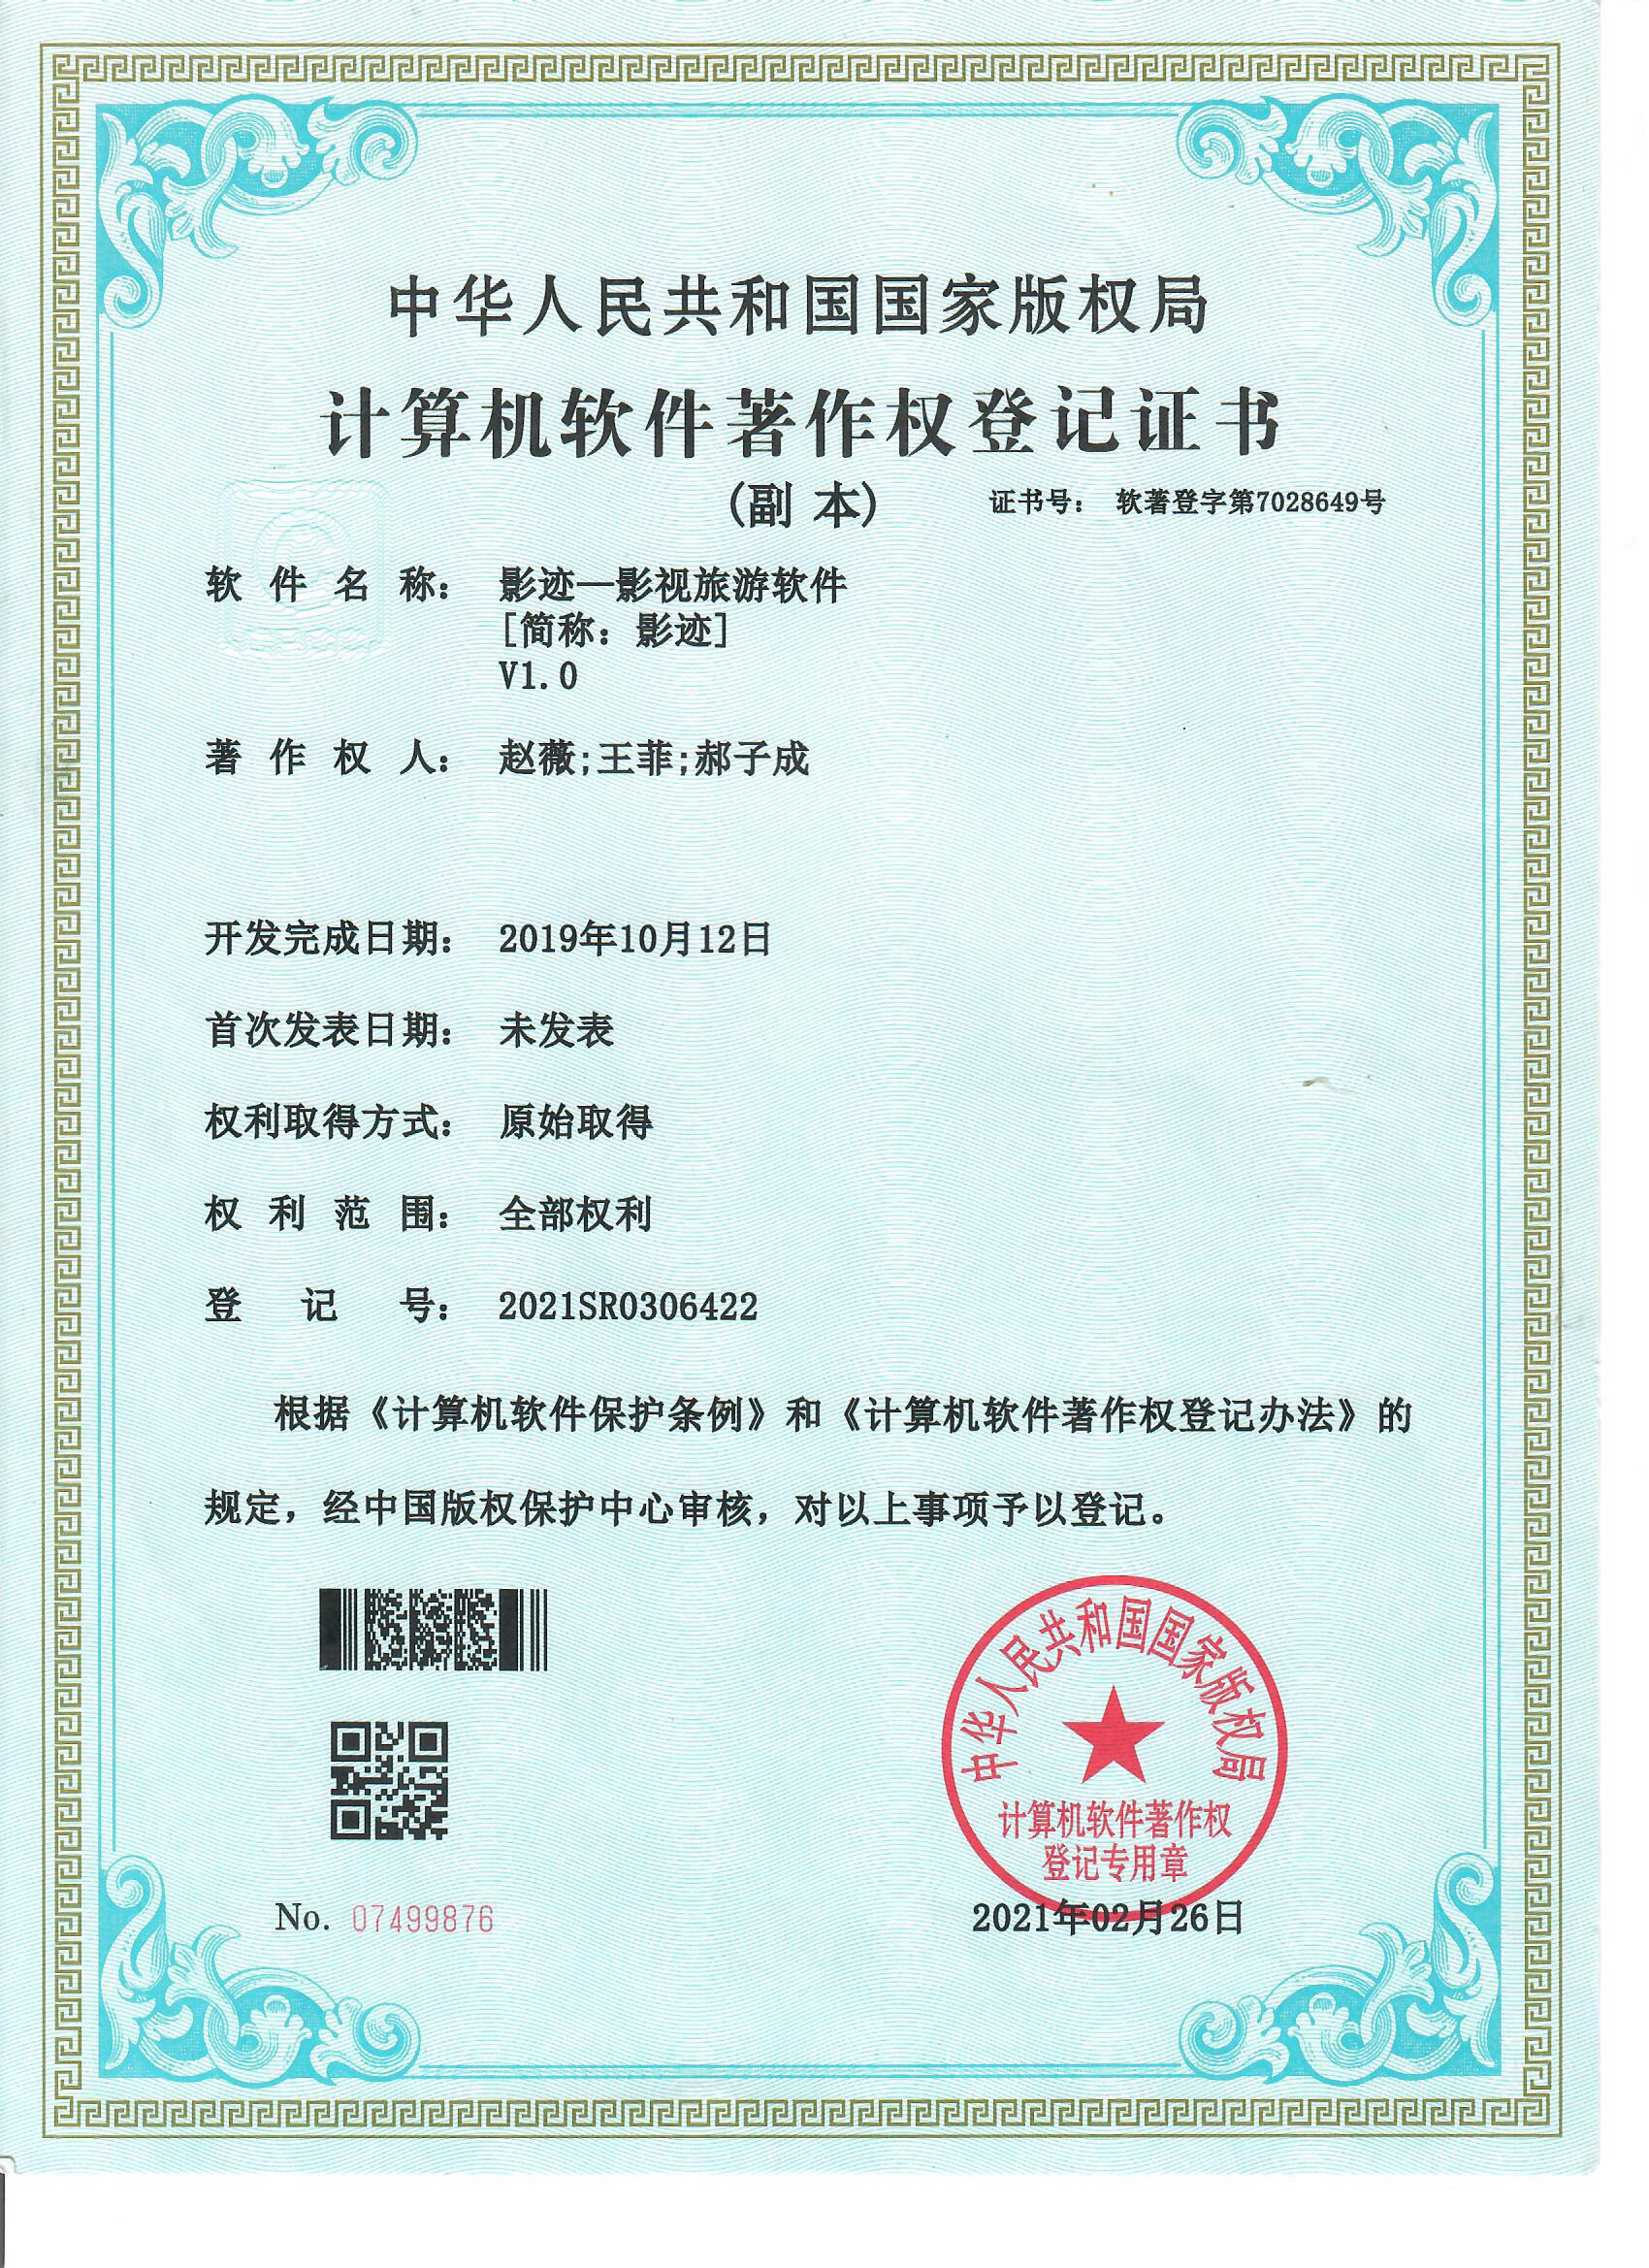
A software system developed based on Springboot, which meets the needs of realizing tourism through films and television.

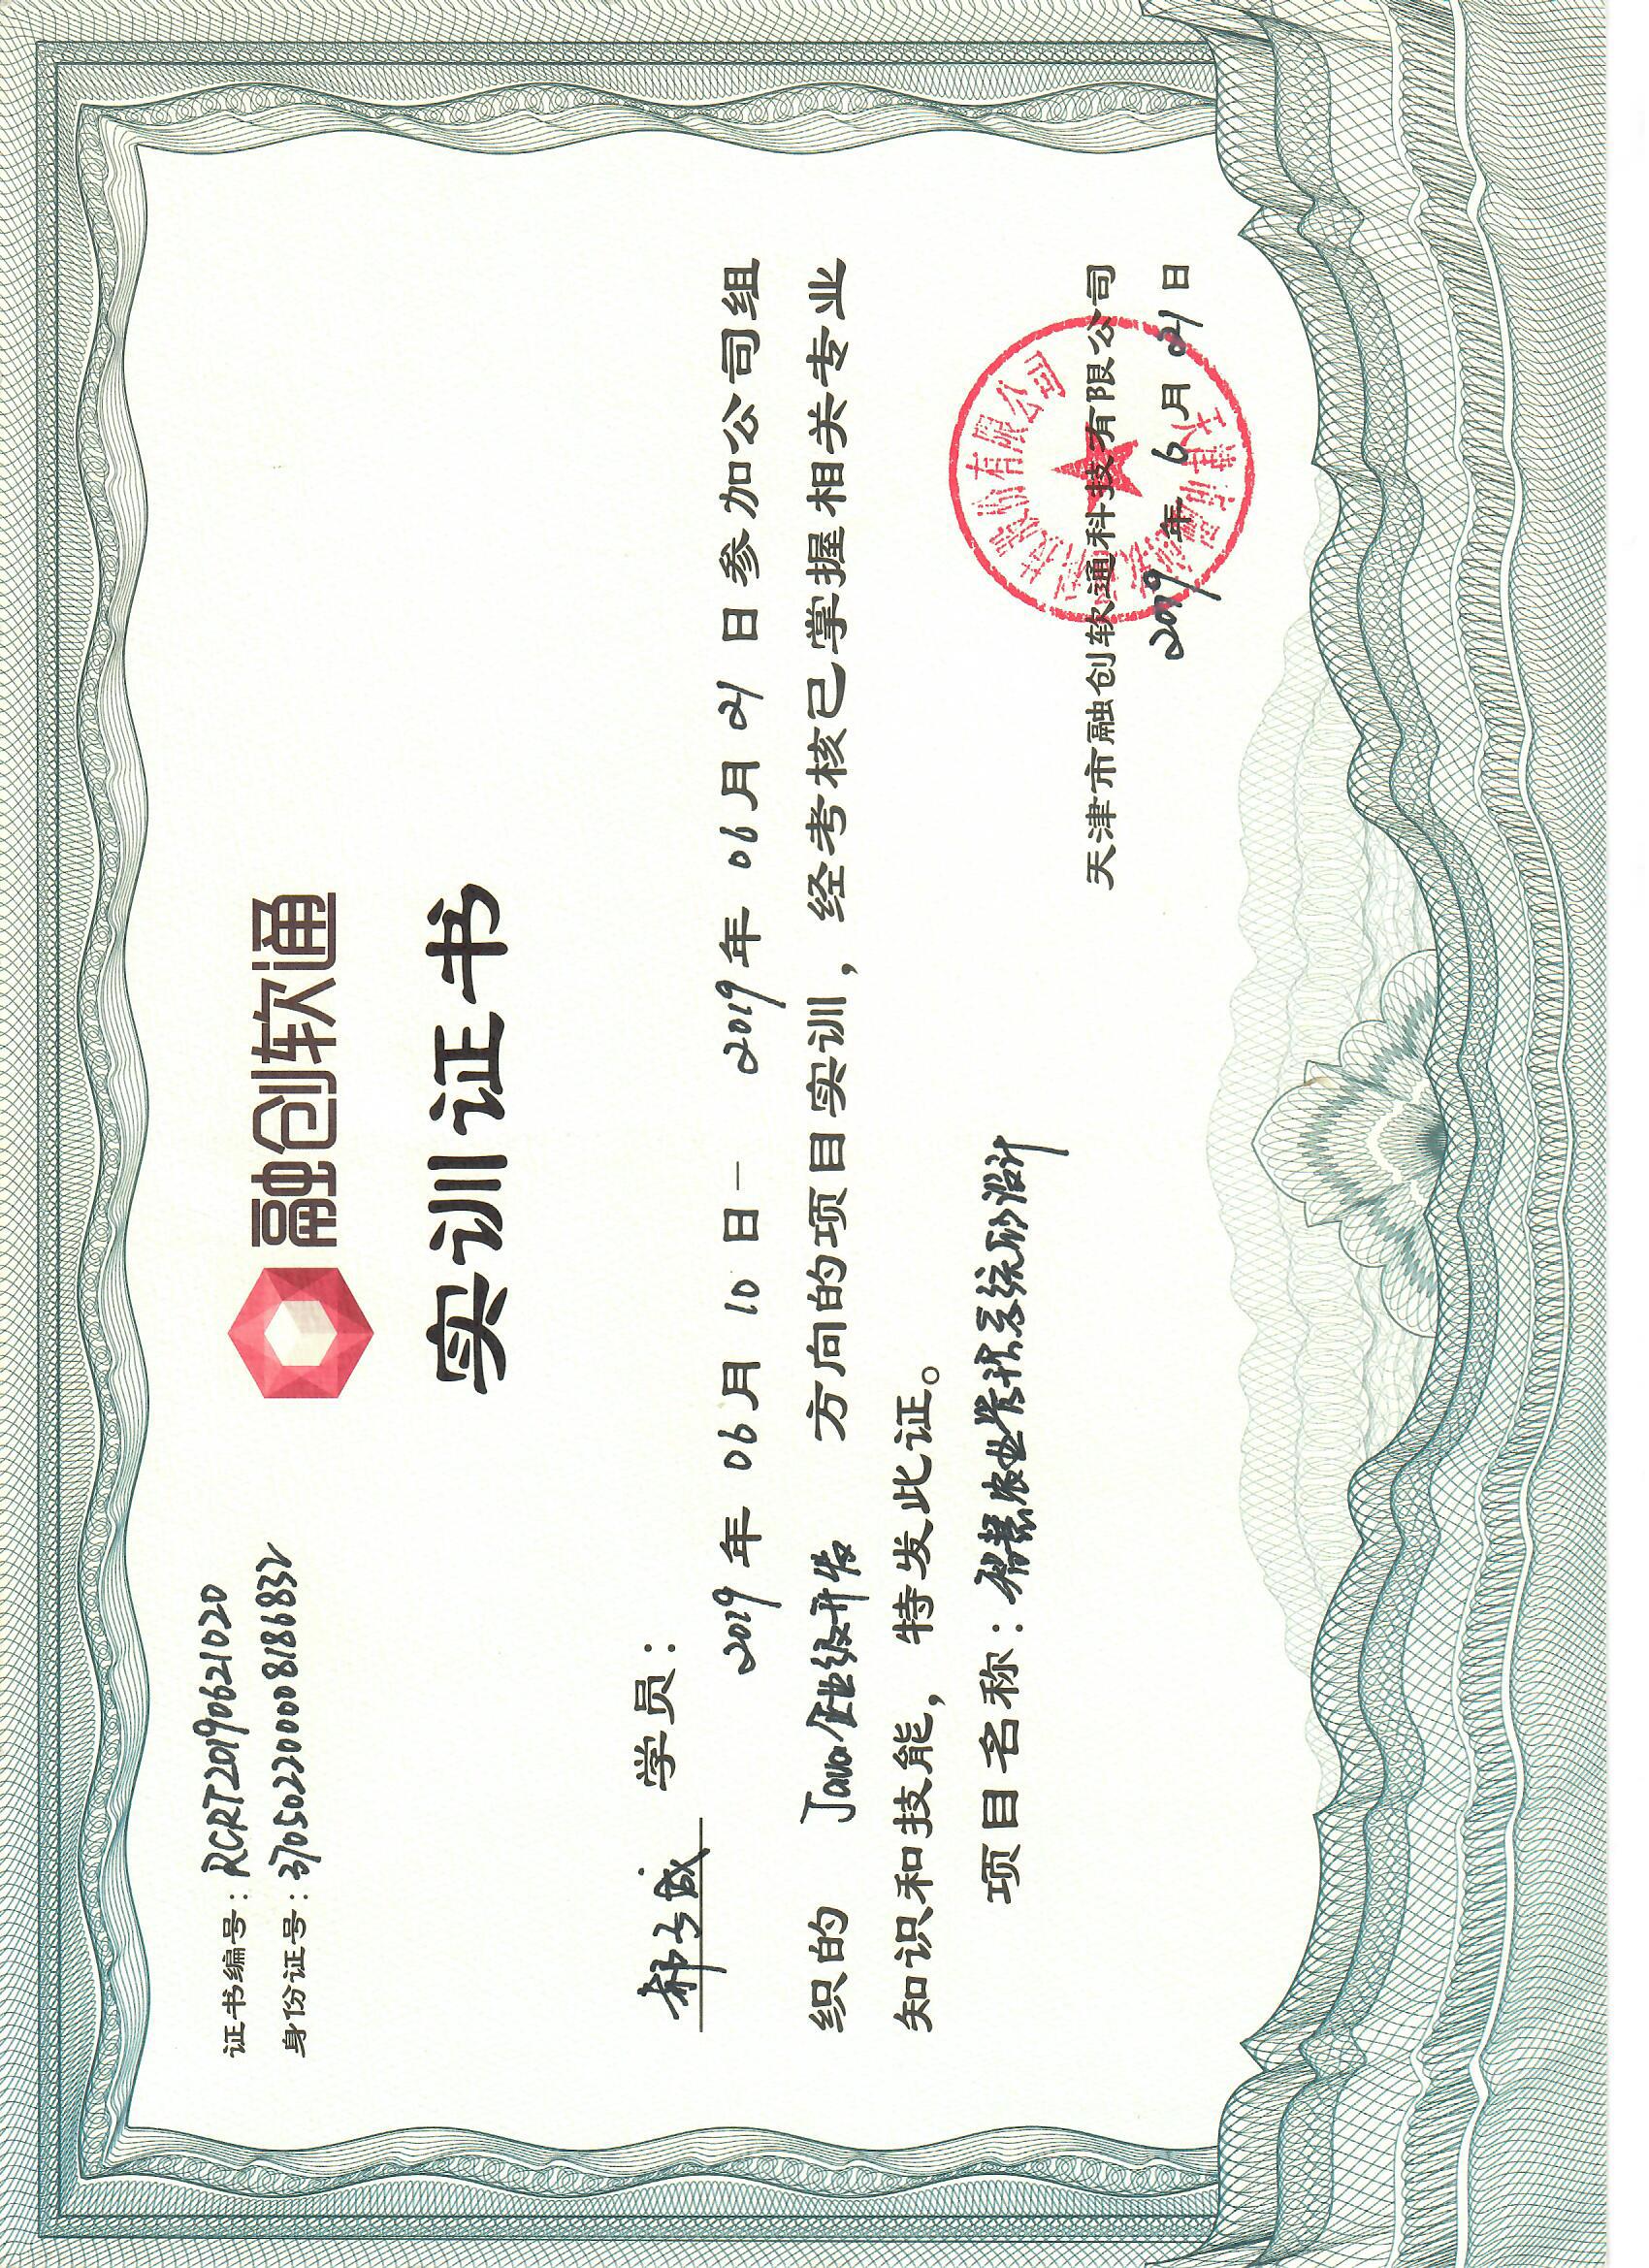
Using sensor monitoring readings to make agriculture more modern, more digital, and more controllable.

Exploring advanced machine learning algorithms and their applications in real-world scenarios. Focus areas include supervised and unsupervised learning, neural networks, and model optimization techniques.